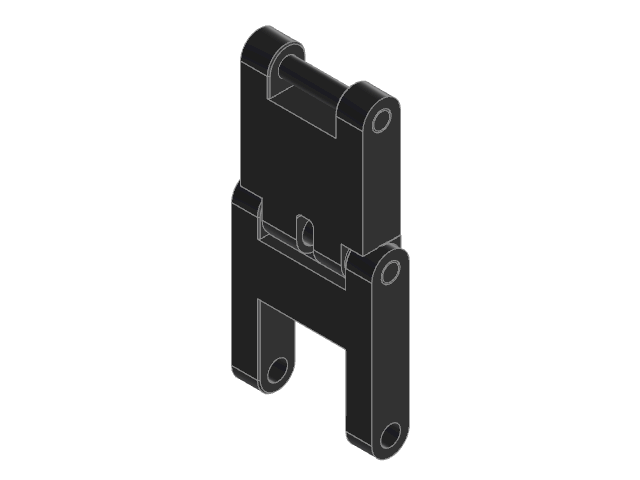
The upper link of an RH-P12-RN(A) finger: ROBOTIS's Link1 and Link2 and the 4 mm shaft between them, one part here, with the 4 mm shaft its far end carries the finger on. The real hand's passive joints let a finger fold round what it meets; held straight, as they are until it does, this link and the lower one keep the finger upright as it opens and closes. Its hub turns in a cradle on the hand's body, 57 mm from that shaft. Taken from ROBOTIS's RH-P12-RN drawing; each hand has two.
- Made by
 ROBOTIS
- Kind
- 3D model
- Licence
- LicenseRef-ROBOTIS-CAD
- Keywords
- robotis, rh-p12-rn, rh-p12-rna, robot hand, gripper, openmanipulator, link, finger, linkage
| Overall size (X × Y × Z) | 8 × 30 × 64.9 mm |
|---|---|
| Type | robot hand link |

