Two-Wheeled Robot
by ReDo.Pro (@ReDo.Pro)
Description
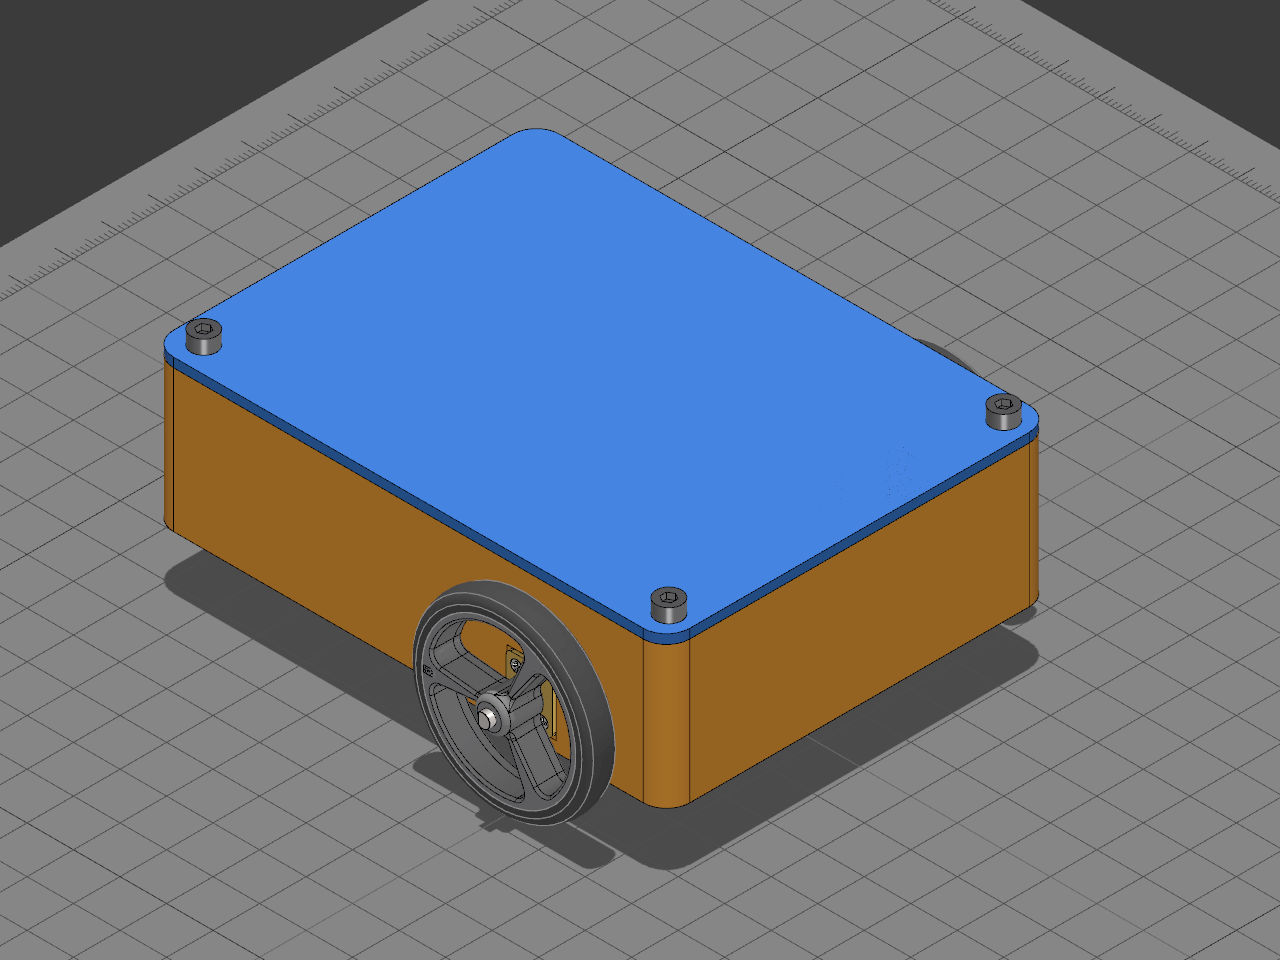
A small two-wheeled robot in a printed case of its own, the one the assistant designs when asked for it.
- **Drive**: two Pololu micro metal gearmotors, 100:1, back to back across the robot, each on a 40 × 7 mm wheel pressed onto its D-shaft. Each motor lies in a saddle on the floor with its front face at the case's side, held down by a printed strap on two M3 screws.
- **Power**: one 18650 cell in its holder between the motors, screwed down to two bosses under the floor. The single cell drives the motors directly, with no boost converter.
- **Brains**: a Feather ESP32 V2 on four M2.5 standoffs, with the DC Motor + Stepper FeatherWing soldered straight onto it with male headers only, no female sockets: the shield stands 7.75 mm above the Feather, the least that clears the Feather's battery socket. The Feather's USB-C comes out of the back wall.
- **Balance**: a 10 mm steel ball in a caster printed under the floor at the back, its bottom level with the wheels'.
- **Case**: a rounded box with a lid on three M3 screws.
Open it in Building Instructions to plan the build step by step.
Bill of materials
- 1 × Micro Metal Gearmotor [100:1, 6 V, precious-metal, none]
- 1 × Micro Metal Gearmotor (2) [100:1, 6 V, precious-metal, none]
- 1 × Battery Holder [18650, 1]
- 1 × Feather Mainboard [ESP32 V2]
- 1 × Steel Ball [⌀10 mm]
- 1 × Robot Chassis
- 1 × Motor Strap
- 1 × Motor Strap (2)
- 1 × Screw [M3, 10 mm, cap]
- 1 × Screw (2) [M3, 10 mm, cap]
- 1 × Screw (3) [M3, 10 mm, cap]
- 1 × Screw (4) [M3, 10 mm, cap]
- 1 × Screw [M3, 8 mm, cap]
- 1 × Screw (2) [M3, 8 mm, cap]
- 1 × Screw [M2.5, 8 mm, cap]
- 1 × Screw (2) [M2.5, 8 mm, cap]
- 1 × Screw (3) [M2.5, 8 mm, cap]
- 1 × Screw (4) [M2.5, 8 mm, cap]
- 1 × DC Motor Driver [Adafruit, 2+, DC Motor + Stepper FeatherWing]
- 1 × Header [male, 16 × 1, 2.54 mm, 8.5 mm]
- 1 × Header [male, 12 × 1, 2.54 mm, 8.5 mm]
- 1 × Cylindrical Battery [18650]
- 1 × Pololu Wheel [40×7]
- 1 × Pololu Wheel (2) [40×7]
- 1 × Robot Lid
- 1 × Screw (5) [M3, 10 mm, cap]
- 1 × Screw (6) [M3, 10 mm, cap]
- 1 × Screw (7) [M3, 10 mm, cap]
Licences
- Micro Metal Gearmotor (precious-metal brushes): CC BY-SA 4.0, credit Pololu. Downloads: STEP, STL and 3MF
- Battery Holder (Parametric): CC BY-SA 4.0, credit ReDo.Pro. Downloads: STEP, STL and 3MF
- Feather ESP32 V2: CC BY-SA 3.0, credit Adafruit. Downloads: STEP, STL and 3MF
- Steel Ball: CC BY-SA 4.0, credit ReDo.Pro. Downloads: STEP, STL and 3MF
- Screw: CC BY-SA 4.0, credit ReDo.Pro. Downloads: STEP, STL and 3MF
- DC Motor + Stepper FeatherWing: CC BY-SA 3.0, credit Adafruit. Downloads: STEP, STL and 3MF
- Header: CC BY-SA 4.0, credit ReDo.Pro. Downloads: STEP, STL and 3MF
- Cylindrical Battery (Parametric): CC BY-SA 4.0, credit ReDo.Pro. Downloads: STEP, STL and 3MF
- Pololu Wheel 40×7mm: CC BY-SA 4.0, credit Pololu. Downloads: STEP, STL and 3MF