ROBOTIS OpenMANIPULATOR-P with RH-P12-RN(A) Gripper
by ReDo.Pro (@ReDo.Pro)
Description
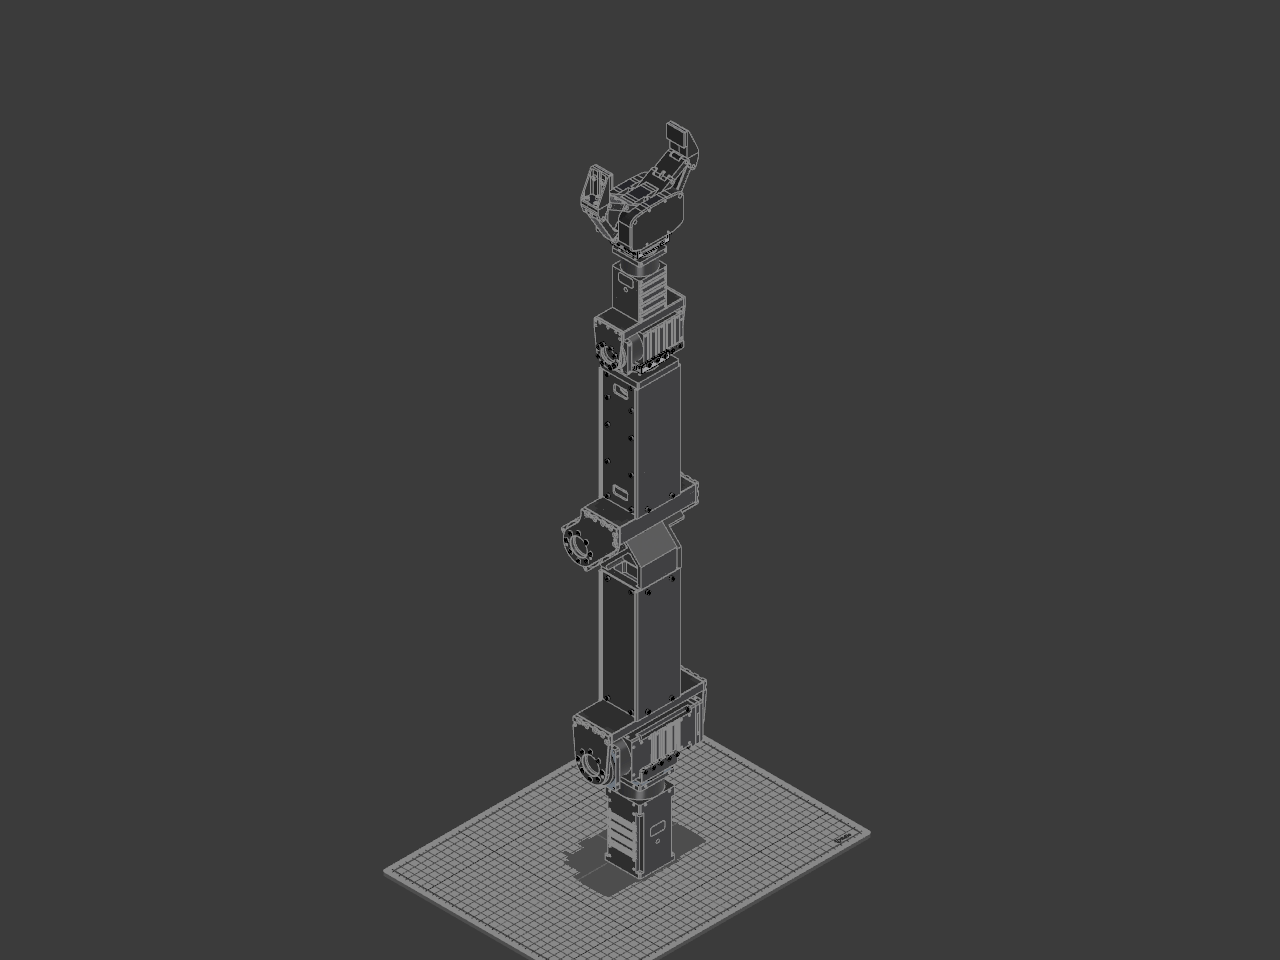
ROBOTIS's OpenMANIPULATOR-P (RM-P60-RNH) with the hand ROBOTIS sell for it, the RH-P12-RN(A), on joint 6. The arm is the six-axis arm of the OpenMANIPULATOR-P tutorial, every actuator, frame and cover ROBOTIS's own and placed where their drawing puts it, standing straight up. The hand is ROBOTIS's drawing of it, placed as the RH-P12-RN(A) Robot Hand tile places it, fingers open and each on its own two links, on the FRP42-A110K adaptor that ships with it.
## How it is built
- **The arm.** Six DYNAMIXEL-P actuators: two PH54-200-S500-R for the base and shoulder, two PH54-100-S500-R for the elbow and forearm twist, two PH42-020-S300-R for the wrist. Each turns its output flange from the Control panel, and the hub of each of the three idler bearing frames turns with the actuator on its axis. Joint 1's case stands grounded, so each joint turns what hangs off its flange, the hand on joint 6 among it.
- **The adaptor.** An FRP42-A110K bolts to joint 6's output flange with eight M3 screws, through the eight of its plate's twenty holes that lie on the flange's bolt circle, into the flange's eight M3 taps. Their heads sit under the hand, in the gap the adaptor's six bosses leave, one at each corner and one halfway along each flange.
- **The hand.** The RH-P12-RN(A) stands on those bosses between the adaptor's two side flanges, held by twelve M3 screws: six through each flange into the six taps along that side of its base. The adaptor has seven holes along each flange, 6 mm apart, and the hand's taps meet all but the middle one. ROBOTIS ship the hand with the adaptor and twenty M3 bolts, as many as the eight into joint 6's flange and these twelve take.
- **The hand itself.** A coreless motor, a 1181:1 gearhead, an absolute encoder and a controller of its own, on the same RS-485 bus at 24 V as the arm: it opens 0 to 106 mm and grips at up to 170 N. RH-P12-RN and RH-P12-RN(A) are the same hand; the (A) firmware is the one the OpenMANIPULATOR-P uses.
- **Its fingers.** Each finger turns on an upper link pivoted in a cradle on the body and a lower link on the drive's hub below it, both 57 mm between their pivots, so the finger stays upright as it swings in to close. The real hand's passive joints let a finger fold round what it grips; here they are held straight, as they are until a finger meets something.
- **In Simulation.** The arm's six actuators are motors there, as in the OpenMANIPULATOR-P tutorial: Play turns each at ROBOTIS's continuous speed for its model within the arm's operating range from ROBOTIS's e-manual, joints 2, 3 and 5 back and forth and joints 1, 4 and 6 round and round, the hand riding on joint 6. Drag a finger, or turn or put a motor on one of its pivots, and it opens or closes on its links. Each finger moves on its own, since nothing yet couples the two through the hand's gears, and the hand's own motor is not one here.
## Build it
1. Build the arm as the OpenMANIPULATOR-P tutorial does, from the base plate to joint 6.
2. Turn joint 6 to its zero, then bolt the FRP42-A110K's plate to its output flange with eight M3 screws from inside the adaptor.
3. Set the hand on the adaptor's bosses, between its side flanges, and screw it in with six M3 screws through each flange, leaving each flange's middle hole empty.
4. Run the hand's cable to the arm's bus, and choose the (A) firmware in DYNAMIXEL Wizard if it is not already on it.
ROBOTIS ship the arm and the hand in one case when bought together. The drawing of the arm with its gripper is 767.3 mm long, and the hand's jaws open 108 mm.
Bill of materials
- 1 × PH54-200-S500-R, joint 1
- 1 × FRP54-A110K, base
- 1 × PH54-200-S500-R, joint 2
- 1 × FRP54-H030K, joint 2
- 1 × FRP54-I110K, joint 2
- 1 × Shoulder hinge
- 1 × FRP54-P162K M1, upper arm
- 1 × FRP54-A130, elbow
- 1 × PH54-100-S500-R, joint 3
- 1 × FRP54-I110K, joint 3
- 1 × Elbow hinge
- 1 × FRP54-P162K M2, forearm
- 1 × PH54-100-S500-R, joint 4
- 1 × FRP54-T2, wrist
- 1 × FRP54-T3, forearm end
- 1 × FRP42-A110K, wrist
- 1 × PH42-020-S300-R, joint 5
- 1 × FRP42-I110K, joint 5
- 1 × Wrist hinge
- 1 × PH42-020-S300-R, joint 6
- 1 × Wrist cover
- 1 × Elbow cover
- 1 × FRP42-A110K, gripper
- 1 × RH-P12-RN(A) Body
- 1 × RH-P12-RN(A) Lower Link
- 1 × RH-P12-RN(A) Upper Link
- 1 × RH-P12-RN(A) Finger
- 1 × RH-P12-RN(A) Upper Link (2)
- 1 × RH-P12-RN(A) Lower Link, Mirrored
- 1 × RH-P12-RN(A) Finger (2)
- 8 × Screw M3 × 8 · PH54-200-S500-R, joint 1
- 18 × Screw M3 × 8 · PH54-200-S500-R, joint 2
- 7 × Screw M3 × 8 · FRP54-I110K, joint 2
- 4 × Screw M3 × 16 · FRP54-I110K, joint 2
- 8 × Screw M3 × 8 · Shoulder hinge
- 8 × Screw M3 × 8 · FRP54-A130, elbow
- 18 × Screw M3 × 8 · PH54-100-S500-R, joint 3
- 2 × Screw M3 × 6 · PH54-100-S500-R, joint 3
- 7 × Screw M3 × 8 · FRP54-I110K, joint 3
- 4 × Screw M3 × 10 · FRP54-I110K, joint 3
- 8 × Screw M3 × 8 · Elbow hinge
- 8 × Screw M3 × 8 · PH54-100-S500-R, joint 4
- 12 × Screw M3 × 6 · PH54-100-S500-R, joint 4
- 4 × Screw M3 × 8 · FRP54-T2, wrist
- 2 × Screw M3 × 5 · FRP54-T3, forearm end
- 2 × Screw M3 × 4 · FRP54-T3, forearm end
- 14 × Screw M3 × 8 · PH42-020-S300-R, joint 5
- 4 × Screw M3 × 6 · PH42-020-S300-R, joint 5
- 4 × Screw M3 × 10 · PH42-020-S300-R, joint 5
- 8 × Screw M3 × 8 · FRP42-I110K, joint 5
- 12 × Screw M3 × 8 · PH42-020-S300-R, joint 6
- 12 × Screw M3 × 10 · RH-P12-RN(A) Body
Licences
- DYNAMIXEL-P PH54-200-S500-R: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- FRP54-A110K Adaptor Frame: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- FRP54-H030K Spacer: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- FRP54-I110K Idler Bearing Frame: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- OpenMANIPULATOR-P Shoulder Hinge: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- FRP54-P162K M1 Profile: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- FRP54-A130 Elbow Adaptor: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- DYNAMIXEL-P PH54-100-S500-R: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- OpenMANIPULATOR-P Elbow Hinge: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- FRP54-P162K M2 Profile: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- FRP54-T2 Twist Cap: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- FRP54-T3 Twist Cap: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- FRP42-A110K Adaptor Frame: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- DYNAMIXEL-P PH42-020-S300-R: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- FRP42-I110K Idler Bearing Frame: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- OpenMANIPULATOR-P Wrist Hinge: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- OpenMANIPULATOR-P Wrist Cover: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- OpenMANIPULATOR-P Elbow Cover: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- RH-P12-RN(A) Body: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- RH-P12-RN(A) Lower Link: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- RH-P12-RN(A) Upper Link: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- RH-P12-RN(A) Finger: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- RH-P12-RN(A) Lower Link, Mirrored: LicenseRef-ROBOTIS-CAD, credit ROBOTIS. Downloads: no downloads
- Screw: CC-BY-SA-4.0, credit ReDo.Pro. Downloads: STEP, STL and 3MF