ROBOTIS TurtleBot3 Burger
by ReDo.Toys (@ReDo.Toys)
Description
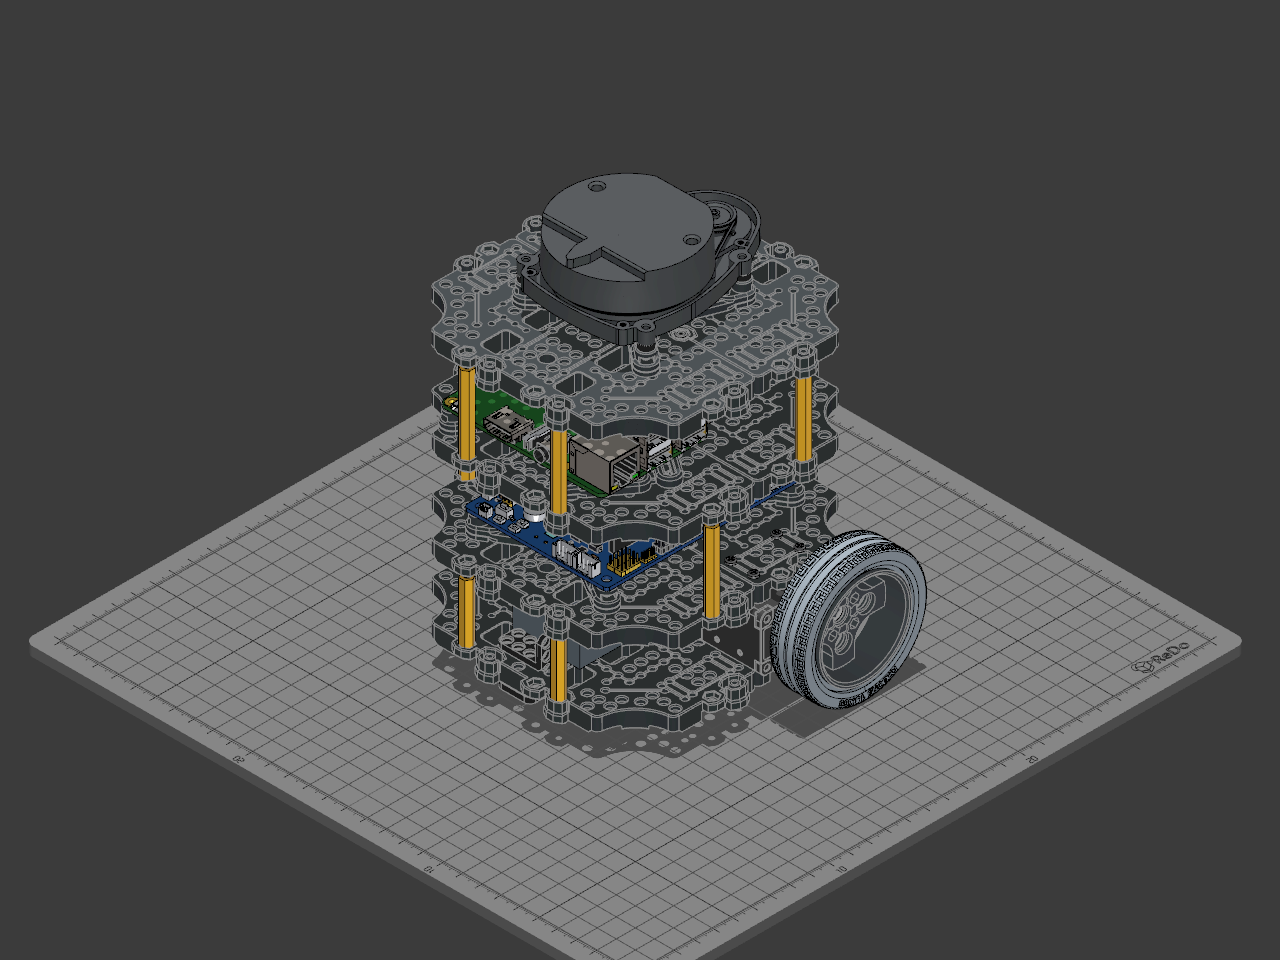
ROBOTIS's TurtleBot3 Burger: the small, round, four-floor mobile robot that is the standard platform for learning ROS. Two DYNAMIXEL XL430s drive its wheels, a ball caster carries its tail, an OpenCR 1.0 runs the motors and the motion sensor, a Raspberry Pi runs ROS, and the LDS-01 lidar on top spins to map the room. It is 138 × 178 × 192 mm, weighs about 1 kg, and drives at up to 0.22 m/s for about two and a half hours on its 11.1 V battery. Every part is the Inventory's own, taken from ROBOTIS's published model of the robot and placed where that model puts it, with what the model gets wrong corrected from ROBOTIS's part drawings and assembly manual.
## How it is built
- **The chassis.** Each floor is two TB3 Waffle Plates bolted edge to edge with four M3 screws and nuts. Floor 1 stands on plate supports M3 × 35 to floor 2, and floors 2 to 4 on M3 × 45. Plates, supports, screws and nuts are one group, the Chassis, which moves as one.
- **The drive.** The two XL430-W250-T (ID 1 on the left, ID 2 on the right) are held to floor 1 by eight M2.6 × 12 tapping screws each, from underneath. Each TB3 Wheel with Tire is held to its servo's horn by four M2 × 4 screws, so turning a servo from the Control panel turns its wheel. The ball caster is screwed under the rear of floor 1 with four M2 × 6 screws, and its 3/8 in steel ball rolls in it.
- **The power.** The LB-012 Li-Po battery (11.1 V, 1800 mAh) lies on floor 1 between the two servos, held front and back by five right-angle brackets.
- **The electronics.** The OpenCR 1.0 stands on four PCB supports on floor 2, the Raspberry Pi 3 Model B on four on floor 3 with the USB2LDS beside it, and the LDS-01 on four PCB supports and four spacers on floor 4. All three boards are real circuit boards in the Inventory, each chip and connector a part of its own: the OpenCR is built from ROBOTIS's own open-hardware design, with its Arduino sockets, its 2 × 10 header and every pad you can wire to, and the Raspberry Pi's 40 GPIO pins are named.
## What is not fastened yet
ROBOTIS snap the OpenCR, the USB2LDS, the battery brackets and the lidar's spacers in with plastic push rivets, and bolt the PCB supports, the Raspberry Pi and the lidar with M2.5 bolts into nuts slid into the supports. The model leaves these out and the Inventory has no push rivet yet, so those parts stand where they belong but are not joined: moving the chassis leaves them behind. The battery only rests between its brackets, and the caster's ball is loose in its cover, as on the real robot.
## Build it
This is ROBOTIS's own assembly order, from the TurtleBot3 Burger manual.
1. **Floor 1.** Bolt the two waffle plates together (M3 × 8 and nuts, from underneath). Screw the ball caster under the rear. Stand the four M3 × 35 plate supports on top, and fit the five brackets that hold the battery.
2. **The wheels.** Stretch each tyre over its wheel, and screw each wheel onto an XL430's horn with four M2 × 4. Set the left servo to ID 1 and the right to ID 2, and screw both to floor 1 from underneath (M2.6 × 12). Lay the battery between them.
3. **Floor 2.** Bolt the second pair of plates together, fix it on the M3 × 35 supports, and stand the four M3 × 45 supports on it. Fit the four PCB supports, pass the servo cables through, and mount the OpenCR 1.0.
4. **Floor 3.** Bolt the third pair of plates on the M3 × 45 supports and stand four more on it. Fit the PCB supports with an M2.5 nut in each slot, and mount the Raspberry Pi. Rivet the USB2LDS beside it.
5. **Floor 4.** Bolt the top pair of plates on, and mount the LDS-01 on its PCB supports and spacers. Connect the lidar to the USB2LDS, the USB2LDS and the OpenCR to the Raspberry Pi, and the battery to the OpenCR.
Bill of materials
- 4 × Plate support M3 × 45, floor 2 to 3
- 4 × PCB support, OpenCR
- 12 × Screw M2.5 × 12
- 1 × OpenCR 1.0
- 16 × Screw M3 × 6
- 1 × Waffle plate, floor 2, front
- 16 × Nut M3
- 1 × Waffle plate, floor 2, rear
- 6 × Plate support M3 × 45, floor 3 to 4
- 4 × PCB support, Raspberry Pi
- 1 × Raspberry Pi 3 Model B
- 1 × Waffle plate, floor 3, front
- 1 × Waffle plate, floor 3, rear
- 1 × USB2LDS
- 5 × Battery bracket
- 4 × Plate support M3 × 35, floor 1 to 2
- 1 × Caster ball (3/8 in steel)
- 1 × Ball caster
- 1 × XL430-W250-T, left wheel (ID 1)
- 1 × TB3 Wheel with Tire, left
- 1 × LB-012 Li-Po battery
- 1 × XL430-W250-T, right wheel (ID 2)
- 1 × TB3 Wheel with Tire, right
- 1 × Waffle plate, floor 1, front
- 1 × Waffle plate, floor 1, rear
- 4 × LDS spacer
- 4 × PCB support, LDS
- 1 × Waffle plate, floor 4, front
- 1 × Waffle plate, floor 4, rear
- 1 × LDS-01 lidar
- 4 × Screw M2 × 4 · XL430-W250-T, left wheel (ID 1)
- 4 × Screw M2 × 4 · XL430-W250-T, right wheel (ID 2)
- 4 × Screw M2 × 6 · Waffle plate, floor 1, rear
- 8 × Screw M2.6 × 12 · XL430-W250-T, left wheel (ID 1)
- 8 × Screw M2.6 × 12 · XL430-W250-T, right wheel (ID 2)
Licences
- Hex Spacer: CC BY-SA 4.0, credit ReDo.Pro. Downloads: STEP, STL and 3MF
- TB3 PCB Support: Maker's own terms, credit ROBOTIS. Downloads: no downloads
- Screw: CC BY-SA 4.0, credit ReDo.Pro. Downloads: STEP, STL and 3MF
- OpenCR 1.0: CC BY-SA 4.0, credit ROBOTIS. Downloads: STEP, STL and 3MF
- TB3 Waffle Plate: Maker's own terms, credit ROBOTIS. Downloads: no downloads
- Nut: CC BY-SA 4.0, credit ReDo.Pro. Downloads: STEP, STL and 3MF
- Raspberry Pi 3 Model B (TurtleBot3): CC BY-SA 4.0, credit ROBOTIS. Downloads: STEP, STL and 3MF
- USB2LDS: CC BY-SA 4.0, credit ROBOTIS. Downloads: STEP, STL and 3MF
- TB3 Bracket: Maker's own terms, credit ROBOTIS. Downloads: no downloads
- Steel Ball: CC BY-SA 4.0, credit ReDo.Pro. Downloads: STEP, STL and 3MF
- TB3 Ball Caster: Maker's own terms, credit ROBOTIS. Downloads: no downloads
- DYNAMIXEL XL430 / XC430: Maker's own terms, credit ROBOTIS. Downloads: no downloads
- TB3 Wheel with Tire: Maker's own terms, credit ROBOTIS. Downloads: no downloads
- LB-012 Li-Po Battery 11.1 V 1800 mAh: Maker's own terms, credit ROBOTIS. Downloads: no downloads
- TB3 Spacer: Maker's own terms, credit ROBOTIS. Downloads: no downloads
- LDS-01 360° Laser Distance Sensor: Maker's own terms, credit ROBOTIS. Downloads: no downloads