| × 12 | SMD Capacitor0805 | | B44, B60, B81, B84, B96, B97, B106, B107, B112, B113, B116, B119 | X7R SMD MLCC series datasheet (KEMET) |
| × 9 | SMD Capacitor1210 | | B10, B11, B14, B28, B48, B55, B58, B82, B105 | X7R SMD MLCC series datasheet (KEMET) |
| × 8 | SMD Capacitor0402 | | B62, B63, B72, B74, B77, B79, B85, B86 | X7R SMD MLCC series datasheet (KEMET) |
| × 7 | SMD Capacitor0603 | | B33, B35, B39, B41, B47, B50, B56 | X7R SMD MLCC series datasheet (KEMET) |
| × 6 | SMD DiodeSMA | | B26, B43, B49, B68, B103, B104 | |
| × 6 | SOIC / SSOP / TSSOPTSSOP-20 | | B7, B18, B23, B31, B32, B42 | |
| × 5 | SMD Capacitor1206 | | B70, B80, B87, B90, B115 | X7R SMD MLCC series datasheet (KEMET) |
| × 5 | SMD Resistor0402 | | B65, B66, B71, B75, B78 | RC_L series datasheet (Yageo) |
| × 3 | JST EH 3-Pin Header, B3B-EH-A | | B34, B46, B61 | |
| × 3 | JST EH 4-Pin Header, B4B-EH-A | | B83, B92, B99 | |
| × 3 | QFN / DFNQFN-16 3x3 P0.5 | | B36, B69, B109 | |
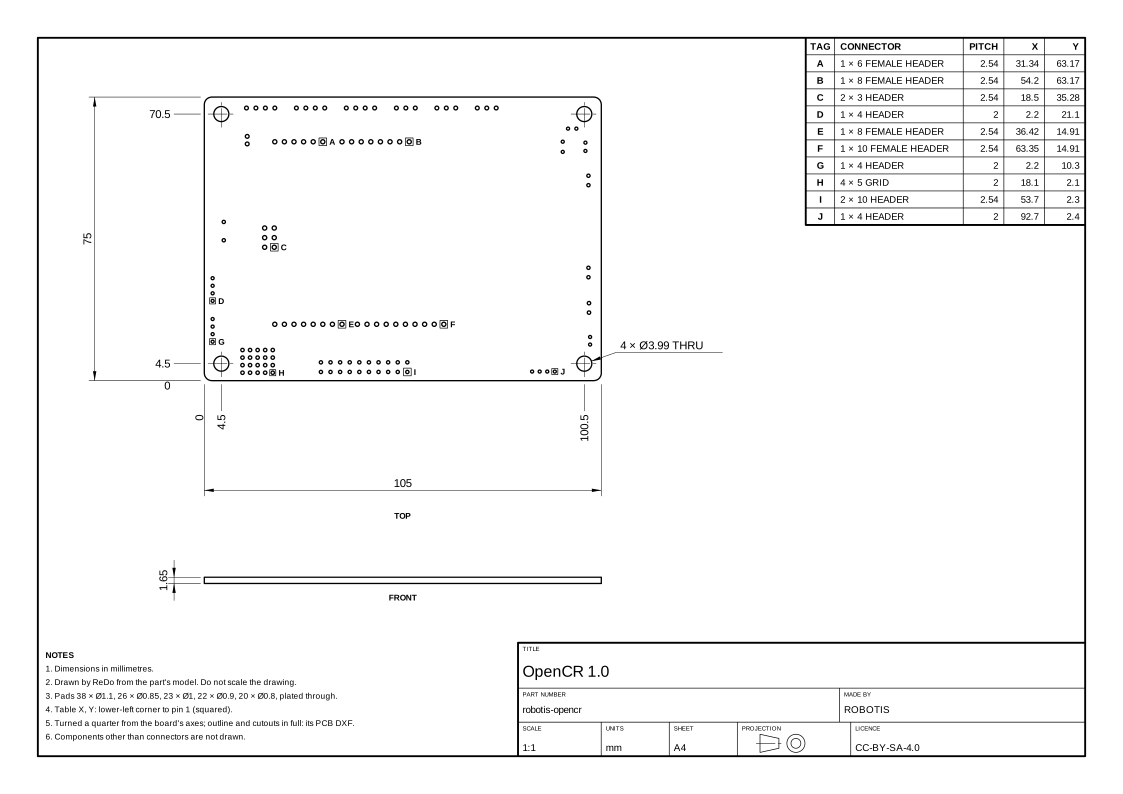
| × 3 | ROBOTIS Component, 4.9 x 2.9 x 2.0 mm (grey) | | B118, B122, B123 | |
| × 3 | ROBOTIS Component, 10.0 x 4.7 x 5.6 mm (grey) | | B17, B120, B121 | |
| × 3 | SMD Electrolytic Capacitor5x5.4 | | B52, B53, B54 | UCD series datasheet (Nichicon) |
| × 2 | DPAK / D2PAKTO-263-5 | | B30, B40 | |
| × 2 | Headerfemale · 8 · 1 | | B64, B91 | SSW through-hole female socket datasheet (Samtec) |
| × 2 | QFN / DFNTDSON-8 | | B27, B38 | |
| × 2 | ROBOTIS Component, 9.5 x 8.3 x 10.0 mm (grey) | | B19, B20 | |
| × 2 | ROBOTIS Component, 12.0 x 10.3 x 10.0 mm (grey) | | B12, B13 | |
| × 2 | SMD Power InductorANR4020 | | B73, B89 | |
| × 2 | SMD Resistor0805 | | B76, B110 | RC_L series datasheet (Yageo) |
| × 2 | SMW250-02 Power Connector | | B4, B5 | |
| × 2 | SOIC / SSOP / TSSOPSOT-223 | | B15, LM1117 | |
| × 2 | SOIC / SSOP / TSSOPSOIC-8 | | B21, B98 | |
| × 1 | DC Barrel Jack, CUI PJ-102A | | B2 | |
| × 1 | DPAK / D2PAKTO-252-2 | | B22 | |
| × 1 | Headerfemale · 10 · 1 | | B51 | SSW through-hole female socket datasheet (Samtec) |
| × 1 | Headermale · 10 · 2 | | B67 | TSW through-hole male header datasheet (Samtec) |
| × 1 | Headerfemale · 6 · 1 | | B94 | SSW through-hole female socket datasheet (Samtec) |
| × 1 | Headermale · 3 · 2 | | B101 | TSW through-hole male header datasheet (Samtec) |
| × 1 | ROBOTIS Component, 4.0 x 2.0 x 6.0 mm (tan) | | B108 | |
| × 1 | ROBOTIS Component, 4.2 x 3.2 x 4.2 mm (grey) | | B124 | |
| × 1 | ROBOTIS Component, 4.7 x 3.3 x 0.2 mm (tinted) | | B111 | |
| × 1 | ROBOTIS Component, 6.0 x 4.7 x 5.6 mm (grey) | | B3 | |
| × 1 | ROBOTIS Component, 6.4 x 3.4 x 4.0 mm (tan) | | B95 | |
| × 1 | ROBOTIS Component, 7.0 x 6.6 x 1.6 mm (grey, underside) | | B59 | |
| × 1 | ROBOTIS Component, 7.1 x 6.5 x 4.0 mm (grey) | | B25 | |
| × 1 | ROBOTIS Component, 7.4 x 4.9 x 5.8 mm (grey) | | B6 | |
| × 1 | ROBOTIS Component, 9.7 x 5.0 x 3.8 mm (grey, underside) | | B9 | |
| × 1 | ROBOTIS Component, 9.8 x 8.5 x 1.6 mm (grey, underside) | | B8 | |
| × 1 | ROBOTIS Component, 10.0 x 8.0 x 6.0 mm (tan) | | B102 | |
| × 1 | ROBOTIS Component, 10.2 x 3.5 x 4.5 mm (grey) | | B117 | |
| × 1 | ROBOTIS Component, 10.6 x 10.5 x 3.2 mm (grey) | | B100 | |
| × 1 | ROBOTIS Component, 13.6 x 7.5 x 13.9 mm (tan) | | B16 | |
| × 1 | ROBOTIS Component, 15.1 x 13.5 x 6.7 mm (grey) | | B1 | |
| × 1 | SMD DiodeSMB | | B29 | |
| × 1 | SMD DIP SwitchCopal CHS-02B | | B57 | CHS-02B datasheet (Nidec Components) |
| × 1 | SMD Power InductorSRP1050WA | | B24 | SRP1050WA datasheet (Bourns) |
| × 1 | SOIC / SSOP / TSSOPTSSOP-28 | | B45 | |
| × 1 | SOTSOT-23W | | B37 | |
| × 1 | SOTSC-70-6 | | B114 | |
| × 1 | STM32F746ZGT6 Microcontroller, LQFP-144 | | B88 | |
 ROBOTIS